
Lie Algebras
Prerequisites: Lie Groups. Full path (3 pages)
Intuitive
The Lie algebras consist of infinitesimally small transformations and are used in physics to describe symmetries. Since arbitrarily large continuous transformations can be built up from tiny ones, almost everything that is important about continuous transformations is encoded in the infinitesimal ones.
Formulated differently, Lie algebras describe infinitesimal symmetries.
Concrete
Lie groups describe continuous symmetries. Therefore, we can consider group elements that are arbitrarily close to the identity element. In mathematical terms, we denote a transformation really close to the identity element (which changes nothing at all) by where is, as usual, a small number and is called a generator for reasons that will become clear in a moment.
When this small transformation acts on an object it barely changes anything. Nevertheless, we can repeat such a tiny transformation many, many times to get a large transformation. For example, many small rotations yield a large rotation.
In mathematical terms, this idea of repeating our small transformation many times can be expressed as where denotes how often we repeat the tiny transformation.
Now the idea is that if we have a finite transformation, say a rotation by , we can describe this through the repetition of an infinitesimal (= tiny tiny tiny) transformation. Everything important about the finite transformation is encoded in the infinitesimal transformation.
To realize this idea explicitly, we divide by a large number in order to make sure that we are close to the identity. This means, our transformation close to the identity transformation is now written as
Now, if are interested in the objects that are as close as possible to the identity element, we must consider the limit . At the same time, when we want to get a finite transformation from such a tiny transformation, we must repeat it infinitely often:
In the limit this is exactly the exponential function.
We can now see that it makes sense to say that the mysterious object generates the finite transformation . This is why is called a generator.
For different transformations, for example, rotations around different axes, we have different generators. The set of all generators is the Lie algebra of the group. With the line of thought from above we can now understand how the Lie algebra is the tangent space above the identity.
There is another way to look at the Lie algebra of a given group, that makes use of the Taylor series. The Taylor series of a function is
We can write this more compactly, by recalling the series definition of the exponential function:
This way, we can see the connection to the first approach
Definition:
For a matrix Lie group the corresponding Lie algebra can be defined as the set of matrices that yield for .
The Natural Product of a Lie Algebra:
A group isn't just a set of transformations. It is a set of transformations together with a binary operation that tells us how we can combine group elements. For matrix Lie groups is simply usual matrix multiplication.
Naively, one could think that we can combine Lie algebra elements simply by using , too. However, this is not the case! In general, for two elements of the Lie algebra and , is not an element of the Lie algebra.
The correct connection between and the rule that correctly connects Lie algebra elements is revealed by the famous Baker-Campbell-Hausdorff formula:
On the left hand side of the equation, we have two group elements that we could call, for example and : and . Therefore, On the right hand side there is just one element of the group. In the exponential, we can see how the Lie algebra elements and get combined. Not simply by matrix multiplication, but through the so-called Lie bracket . For matrix Lie groups is simply the commutator: , where denote the matrix multiplication of and . We conclude that although neither nor are necessarily Lie algebra elements, their difference always is!
The natural product of a Lie algebra is not ordinary matrix multiplication, but the Lie bracket.
[The] Lie algebra is completely characterized by its structure constants .
page 93 in "Geometrical methods of mathematical physics" by Schutz
Abstract
A Lie algebra over a field (in physics or ) is a vector space with a bilinear map that is antisymmetric, , and obeys the Jacobi identity In a basis the bracket is fixed by the structure constants, . Physicists usually write group elements as , so that the are Hermitian in unitary representations, and . The two conventions are related by , which gives .
From the group. For a Lie group , the Lie algebra is the tangent space at the identity, identified with the left-invariant vector fields on ; the bracket is the commutator of vector fields. For matrix groups it is the matrix commutator. The exponential map sends to the endpoint of the one-parameter subgroup with . It is a diffeomorphism from a neighbourhood of onto a neighbourhood of , and the Baker-Campbell-Hausdorff formula above shows that the group product near is determined by the bracket alone.
Lie correspondence. Every finite-dimensional real Lie algebra is the Lie algebra of a simply connected Lie group , unique up to isomorphism. Every connected Lie group with the same Lie algebra is a quotient by a discrete subgroup of the centre of , with . Lie algebra homomorphisms lift to group homomorphisms , but not in general to . This is the reason has half-integer spin representations that are representations of but not of .
Structure. The Killing form , with , is invariant under the adjoint action. By Cartan's criterion is semisimple if and only if is non-degenerate, and a semisimple algebra is a direct sum of simple ideals. A general Lie algebra over a field of characteristic zero splits (Levi decomposition) as a semidirect sum of a semisimple subalgebra and the radical , the largest solvable ideal. The Poincaré algebra is an example with and the translations. The complex simple Lie algebras are classified by Dynkin diagrams: the four infinite families , , , and the five exceptional algebras , , , , .
Real forms. A real Lie algebra with is a real form of . For example and are both real forms of , and the complexified Lorentz algebra is , which is why Lorentz representations are labelled by a pair of spins. Every complex semisimple algebra has a compact real form, on which the Killing form is negative definite. In a basis orthonormal with respect to , the structure constants of a compact algebra are totally antisymmetric.
- How is a Lie Algebra able to describe a Group?
- What Information About a Lie Group is Not Encoded in its Lie Algebra?
Why is it interesting?
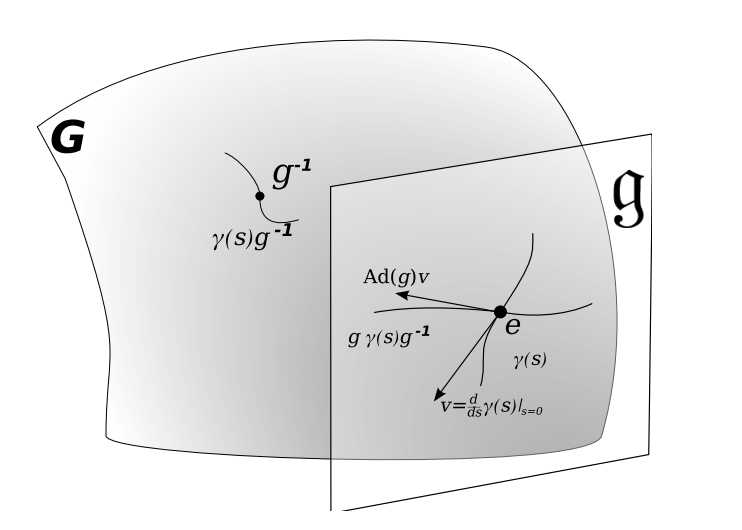
One of the most important ideas of Lie theory is that we can learn a lot about something complicated: a Lie group, by looking at something much simpler: its Lie algebra. A Lie group is a complicated mathematical object (a manifold), whereas a Lie algebra is simply a vector space. A manifold is defined as a set that looks like the good old Euclidean space in the neighborhood of every point. This tangent Euclidean space above each point can be used to define coordinates at each point. The Lie algebra of a given group is defined as the tangent space above the identity element of the group.
Experiment tells us more directly about the Lie algebra of G than about G itself. When I say that G contains the subgroup SU(3) X SU(2) x U(1), I really mean only that the Lie algebra of G contains that of SU(3) X SU(2) X U(1); there is no claim about the global form of G. For the same reason, in later comments I will not be very precise in distinguishing different groups that have the same Lie algebra.
In high-energy theory. we tend to focus on the Lie algebra of a group and ignore its global structure; for example, we indiscriminately refer to the isospin group as SU(2) or SO(3). This is an especially bad habit in monopole theory, because the quantization condition is sensitive to the global structure of G; the allowed set of monopoles is different for SU(2) and SO(3). For example, let us suppose that Q is proportional to , the generator of rotations about the third axis in isospin space. If G is SO(3), Q can be any half-integral multiple of , because a rotation by is the identity. If G is SU(2), though, only integral multiples are allowed, because a rotation by is needed to get back to the identity.
The Magnetic Monopole Fifty Years Later by Sidney R. Coleman
[P]erturbative effects depend only on the Lie algebra.
Global structure of the standard model, anomalies, and charge quantization by Joseph Huck
Path to this page
Leads to: Adjoint Representation, Group Contraction and Deformation.